Location
Shanghai, China
地址
上海

I am currently a System Engineer at Sharpa Robotics. My interests include full-stack novel robot design, minimalism in robotics, swarm robotics, and modular robotics.
I received my B.S. in Physics from Peking University in July 2021 and my Ph.D. in Mechanical Engineering from Northwestern University in July 2026, advised by Prof. Michael Rubenstein. My doctoral work focused on the design, hardware, and control of minimalist robotic systems, including single-motor drone swarms, reconfigurable legged robots, a single-motor spherical robot, and a low-visibility UAV.
I am Gold Medalist in the 18th Asian Physics Olympiad (APhO) in 2017.
Download Resume: English Version | 中文版本
我目前在Sharpa Robotics担任系统工程师,兴趣包括全栈新型机器人设计、极简机器人、集群机器人和模块化机器人。
我于2021年7月获得北京大学物理学院物理学学士学位,2026年7月获得美国西北大学机械工程博士学位,博士导师为Michael Rubenstein教授。博士期间主要从事极简机器人系统的设计、硬件开发与控制研究,包括单旋翼无人机群、可重构足式机器人、单电机球形机器人和低可见度无人机。
我是第18届亚洲物理奥林匹克竞赛(APhO)金牌得主。
简历: 中文版本 | English Version
Major Collaborators: Max Hughes, Prof. Mike Rubenstein
This research advances single-motor drones toward reliable autonomous swarm operation. MP4 implements a custom communication protocol on an FPGA to improve infrared communication reliability and bandwidth, and uses a model-based state estimator and controller to improve flight stability and disturbance recovery. Together, these advances enable stable hovering and four-drone formation flight using onboard peer-to-peer localization, while preserving a mechanically simple, single-motor design.
主要合作者: Max Hughes、Mike Rubenstein教授
该研究推动单电机无人机走向更可靠的自主集群运行。MP4在FPGA上实现定制通信协议,提高红外通信的可靠性与带宽,并采用基于动力学模型的状态估计器和控制器,提升飞行稳定性与扰动恢复能力。这些改进使无人机在保留单电机极简机械结构的同时,实现稳定悬停和基于机载点对点定位的四机编队飞行。
Major Collaborator: Prof. Michael Rubenstein
This research demonstrates the first single motor drone swarm capable of autonomous flight using peer-to-peer (P2P) communication and sensing. Each drone, weighing only 20g and containing just one moving part, can fly independently with full control, featuring onboard P2P communication and precise positioning enabled by a novel infrared-based system. The drone is 10x lighter than all previous systems with comparable P2P positioning accuracy.
主要合作者: Michael Rubenstein教授
该研究开发了首个可自主飞行的单旋翼无人机群并实现了无人机间的相互通信与感知。每架单旋翼无人机仅重20克且仅有一个运动部件,具备自主可控飞行能力,并可依靠创新的红外系统实现高精度定位、通信、与环境感知。该无人机重量比现有的有类似点对点定位同类系统轻10倍。

Major Collaborators: Chen Yu, Prof. Michael Rubenstein
This research presents Phantom Twist, a single-propeller UAV that achieves low visibility by utilizing high-speed rotation and motion blur. We designed an automated design pipeline that optimizes component placement to minimize visual perceptibility while ensuring stable flight.
主要合作者: 余琛, Michael Rubenstein教授
该研究展示了 Phantom Twist:一款利用高速旋转和运动模糊实现低可见性的单旋翼无人机。我们设计了一套自动化设计流程,在确保飞行稳定的前提下,通过优化组件布局最大限度地降低视觉可见度。
论文 | Youtube 视频
Media coverage:媒体报道: Northwestern / IEEE Spectrum / IEEE RAS / 量子位 (QbitAI) / Live Science / Tom's Hardware / New Atlas
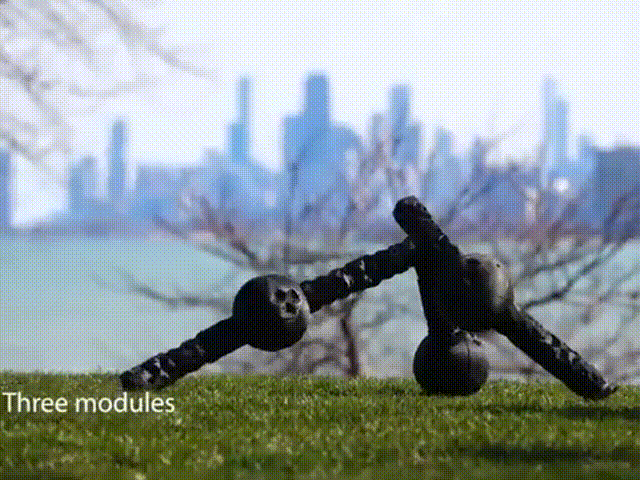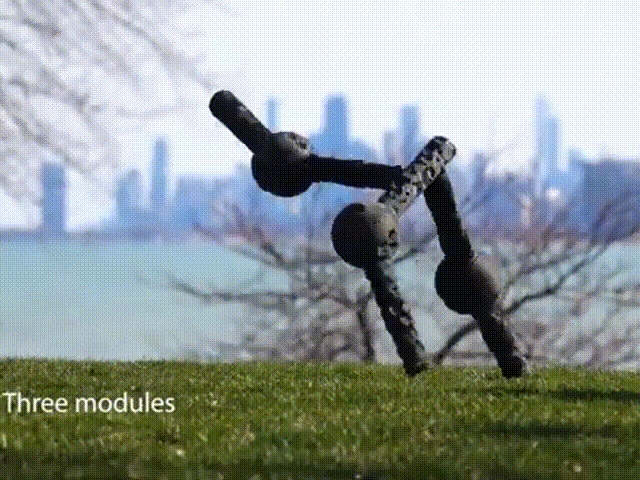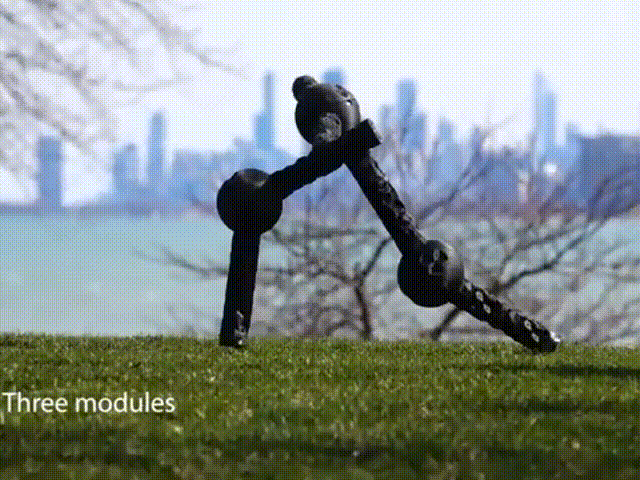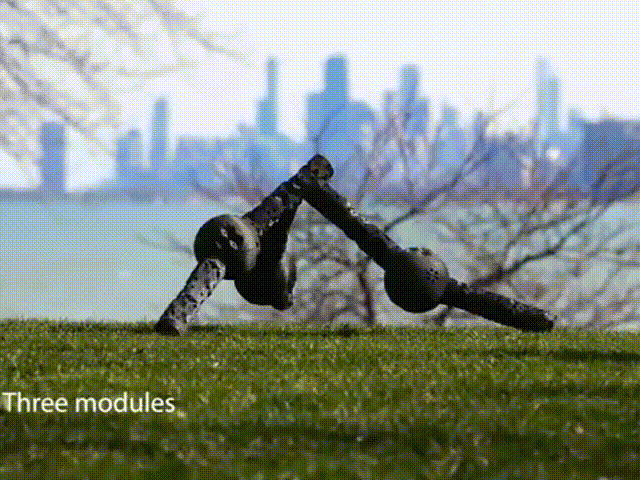
Major Collaborator: Chen Yu, David Matthews, Prof. Sam Kriegman
This research introduces autonomous modular legs: agile yet minimal, single-degree-of-freedom jointed links that can learn complex dynamic behaviors and may be freely attached to form legged metamachines at the meter scale. This research enables rapid repair, redesign, and recombination of highly dynamic modular agents that move quickly and acrobatically through unstructured environments.
Paper | Webpage | Source Code
主要合作者: 余琛, David Matthews, Sam Kriegman教授
该研究提出了一种新型的模块化足式机器人。该机器人单个腿单元中仅包括一个电机及相应控制通信电路,结构极简但具备高动态表现。多个单元组合后可形成更复杂的高动态机器人以适应复杂地形并实现快速重构与自我修复。
Media coverage:媒体报道: Northwestern / Reuters / Live Science / Futurism
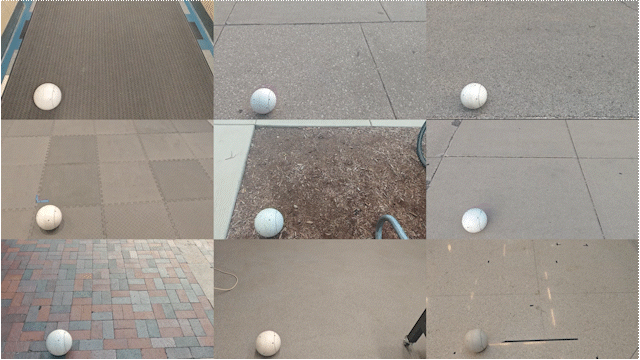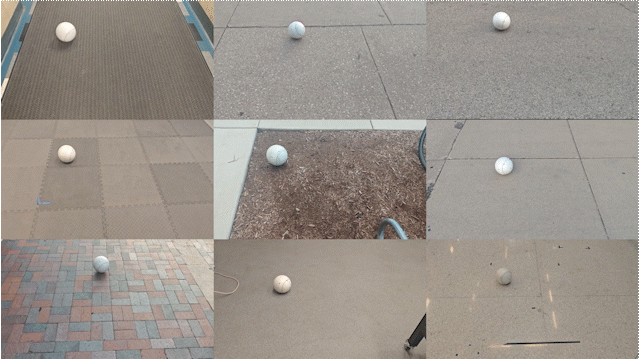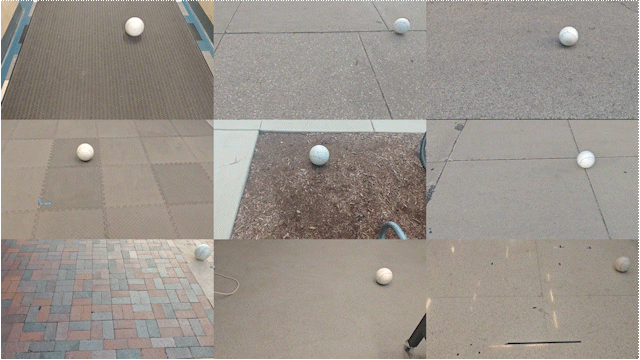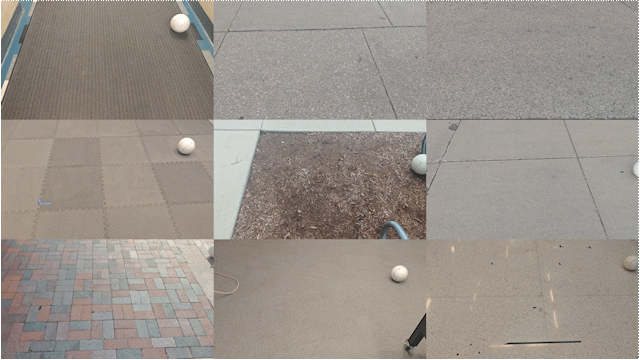
Major Collaborators: Chen Yu, Prof. Mike Rubenstein
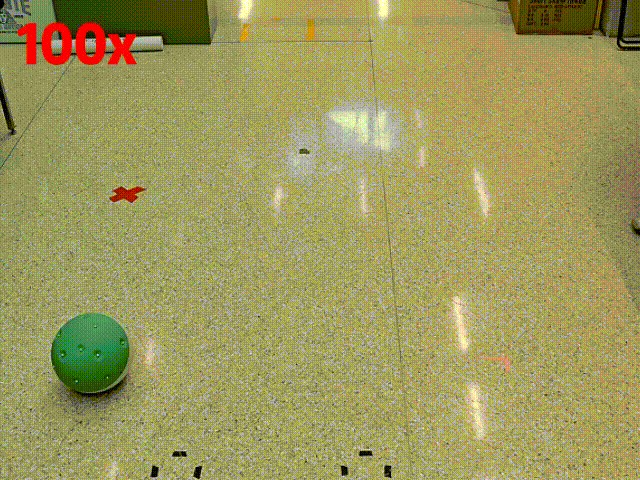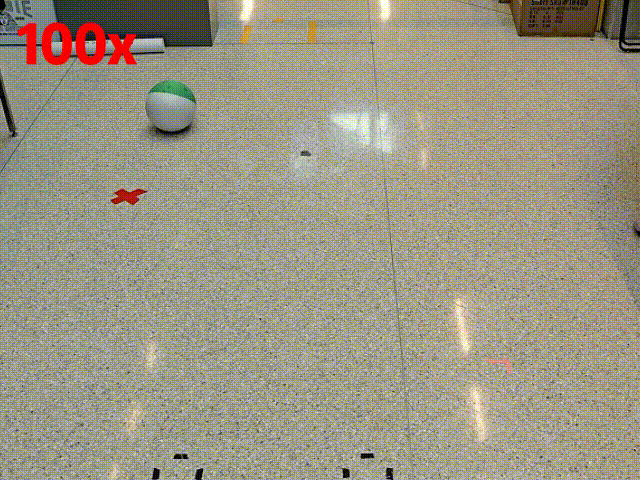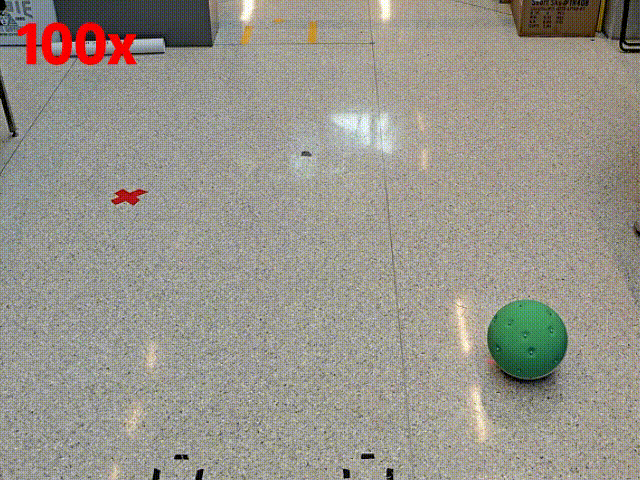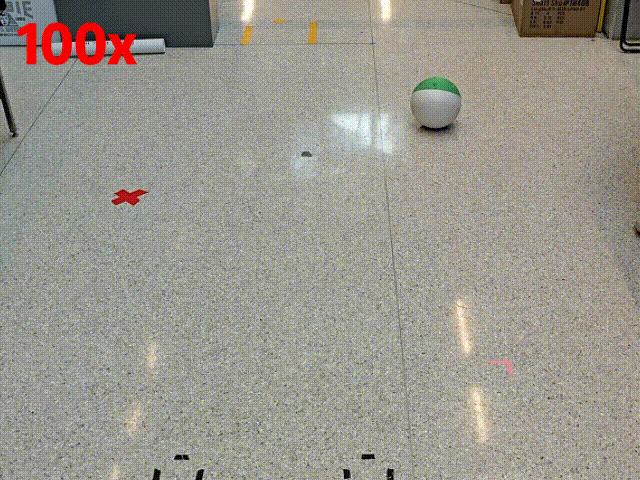
This research demonstrates agile, versatile locomotion with just one motor. Rollbot 2 redesigns the robot's mass distribution to enable continuous straight-line rolling, combines onboard inertial and UWB sensing for navigation, and uses reinforcement learning to control its dynamic motion. These advances enable steering and autonomous beacon seeking beyond motion-capture environments, and more than 70-fold faster traversal than the original Rollbot in its fastest run on a shared path-following benchmark.
主要合作者: 余琛、Mike Rubenstein教授
该研究使仅有一个电机的球形机器人具备更敏捷、多样的运动能力。Rollbot 2通过重新设计质量分布实现连续直线滚动,结合机载惯性与UWB感知进行导航,并利用强化学习控制动态运动。这些改进使机器人能够在动作捕捉环境之外完成转向和自主信标趋近;在相同路径跟踪基准上,最快一次的通过速度比初代Rollbot提升70倍以上。
Major Collaborator: Prof. Michael Rubenstein, Chen Yu
This research presents Rollbot, the first spherical robot that maneuvers on a 2D plane using only a single motor. By modulating motor speed and an attached mass, it controls trajectory curvature to follow circular paths and waypoints. Rollbot has simpler construction and lower cost comparing to conventional multi-motor spherical robots, and can also serve as a fail-safe for multi-motor spherical robots.
主要合作者: Michael Rubenstein教授, 余琛
该研究展示了Rollbot:首个仅使用单个电机在2D平面上机动的球形机器人。通过调制电机转速,它可以控其轨迹并实现可控运动。与传统的多电机球形机器人相比,Rollbot结构更简单、成本更低,还可以作为多电机球形机器人的失效备份。
Major Collaborator: Prof. Mike Rubenstein
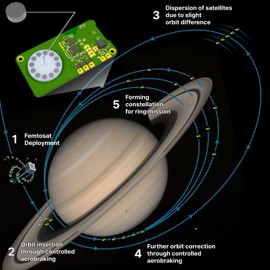
This research explores actively steerable miniature satellites for planetary environments too hazardous for a single spacecraft. The preliminary design couples a PCB-integrated motor with a flexible rod and tip mass for single-motor attitude control, and uses attitude-dependent aerobraking to propose orbital adjustments without propellant. This mechanism and mission co-design could enable a constellation of 10,000 femtosatellites to survey Saturn's rings, upper atmosphere, and magnetosphere, providing distributed coverage and tolerance to individual satellite loss.
主要合作者: Mike Rubenstein教授
该研究探索利用可主动调整姿态的微型卫星,对单颗航天器难以承受风险的行星环境开展探测。预研方案将PCB集成电机与末端带配重的柔性杆相结合,以实现单电机姿态控制,并提出通过调整姿态改变气动制动效果,实现无需推进剂的轨道调整。这种机构与任务协同设计有望支持由10,000颗微型卫星组成的星座,对土星环、高层大气和磁层进行分布式原位观测,同时容忍部分个体损失。
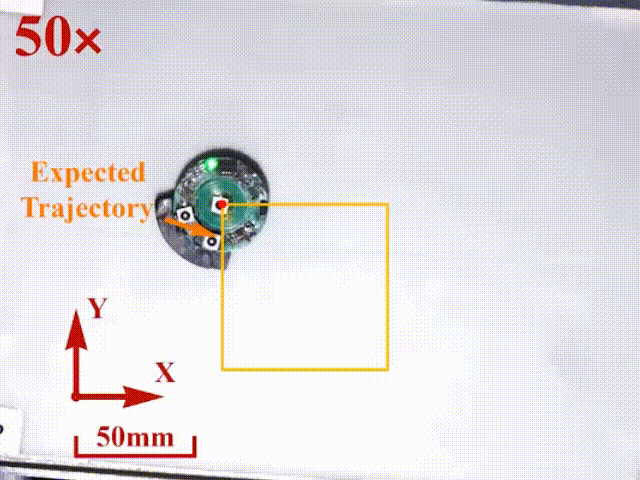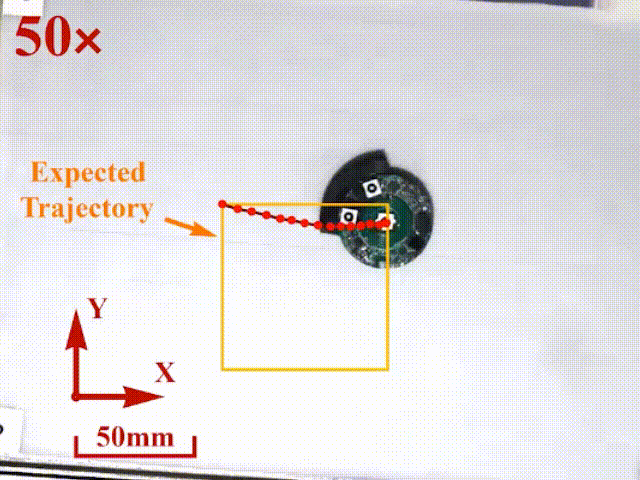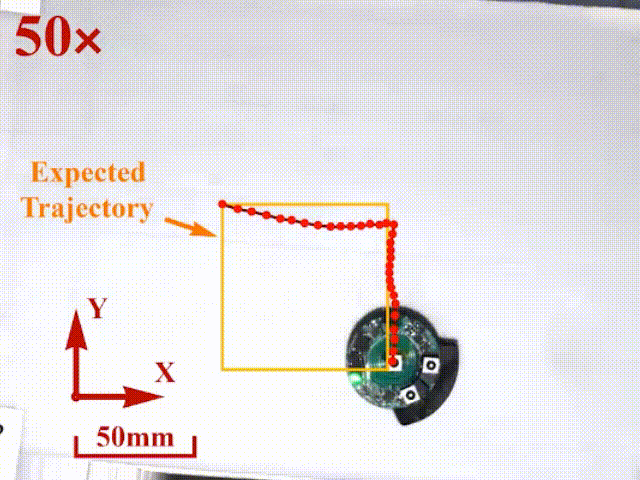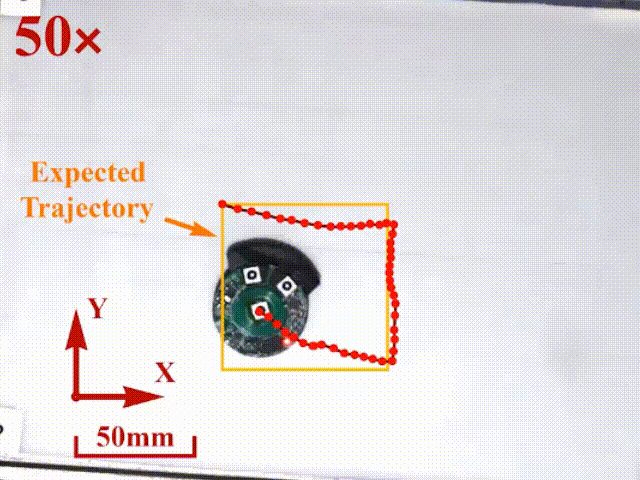
Major Collaborator: Prof. Michael Rubenstein
Best paper finalist, best student paper finalist, best mechanisms and design paper finalist at IROS 2022
This work presents PCBot, a minimalist robot driven by a PCB-integrated bi-stable solenoid actuator. This actuator simplifies manufacturing and reduces assembly time to under 20 seconds. A prototype demonstrates precise motion on an orbital shake table. This research showcases the potential of minimalist, externally-driven designs in robotics.
主要合作者: Michael Rubenstein教授
IROS 2022最佳论文入围奖、最佳学生论文入围奖、最佳机构与设计论文入围奖
该工作提出了PCBot:一种由集成于PCB内的双稳态驱动器驱动的极简机器人。该设计极大地简化了制造过程,组装时间仅20秒。该研究展示了极简、外部驱动设计在机器人学中的应用潜力。
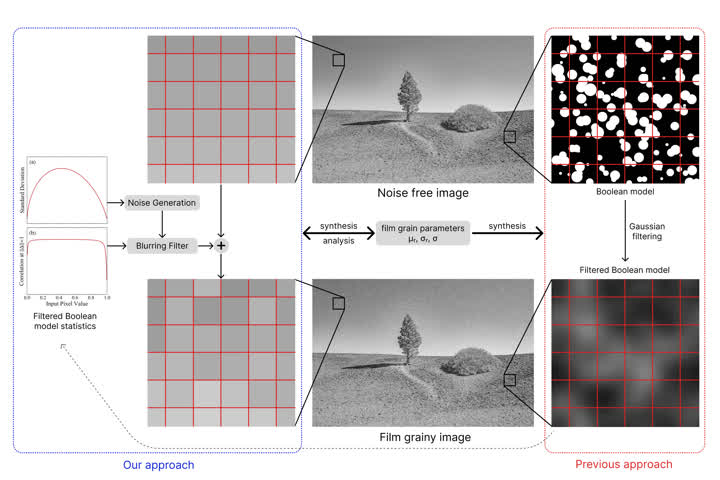
Major Collaborator: Dr. Kaixuan Zhang, Prof. Thrasyvoulos N. Pappas
主要合作者: 张凯旋博士, Thrasyvoulos N. Pappas教授
This research proposes a fast film grain rendering algorithm based on analytic statistics from a physics-based Boolean model used by Newson et al. Our method estimates model parameters from scanned images and enables real-time simulation when individual grains are not visible. Experiments show a six-order speed-up over Newson et al.’s Monte Carlo approach with strong visual fidelity. This work has potential applications in film production, computer graphics, and video compression.
该研究提出了一种快速胶片颗粒特效的渲染算法。我们的方法允许用户从扫描图像中估计模型参数,并实现实时的胶片效果模拟。实验显示我们的方法在比Newson等人提出的蒙特卡罗方法快六个数量级的同时保持了相同的视觉保真度。该工作在电影制作、计算机图形学和视频压缩中具有潜在应用。
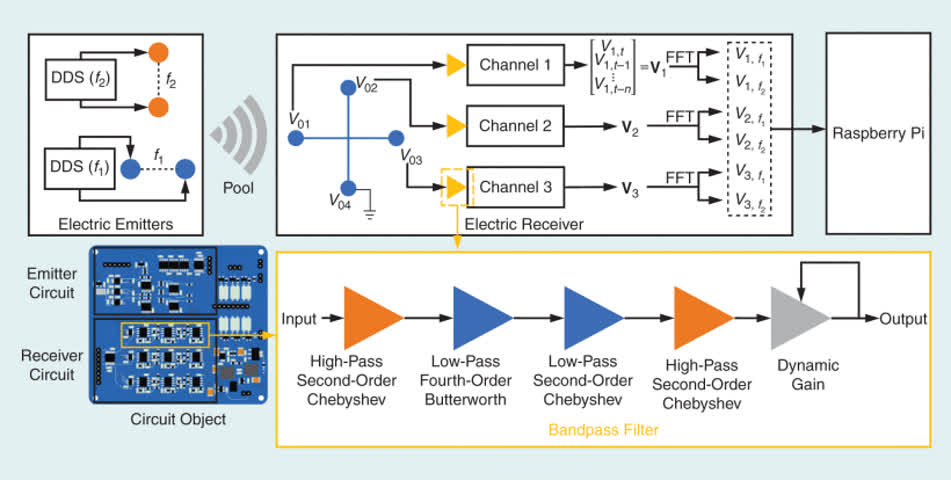
Major Collaborator: Dr. Junzheng Zheng, Xin Guo, Chayutpon Huntrakul, Prof. Chen Wang, Prof. Guangming Xie
This research presents a novel electric sense-based localization scheme for small free-swimming underwater robots in large-scale environments. Inspired by electric sensing in fish, the system uses distributed emitters and an onboard receiver to estimate position and orientation. Experiments demonstrate robust, accurate localization where vision and sonar struggle, offering a lightweight solution for constrained underwater robots.
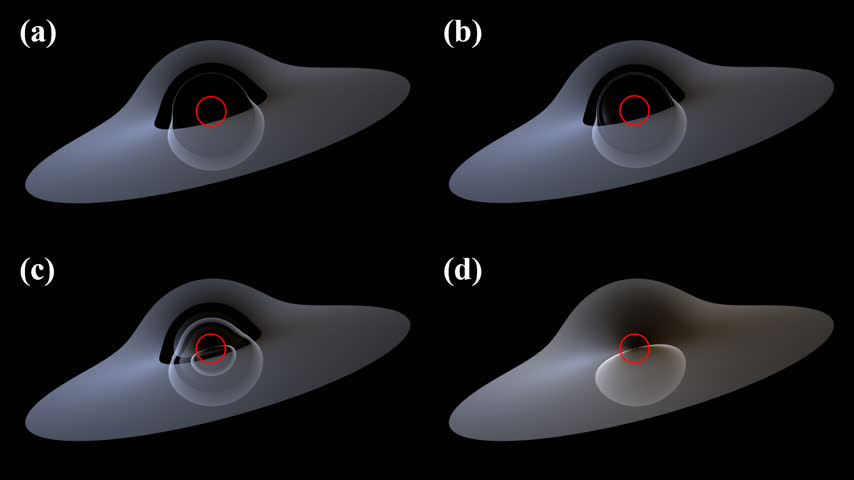
Major Collaborator: Prof. Bin Chen
This paper introduces a double ray-tracing method for fast, physically accurate rendering of accretion disks near spherical spacetimes and used it to render the Schwarzschild black holes and JMN-1 naked singularities.
Major Collaborator: Dr. Shudeng Ma, Prof. Guangming Xie
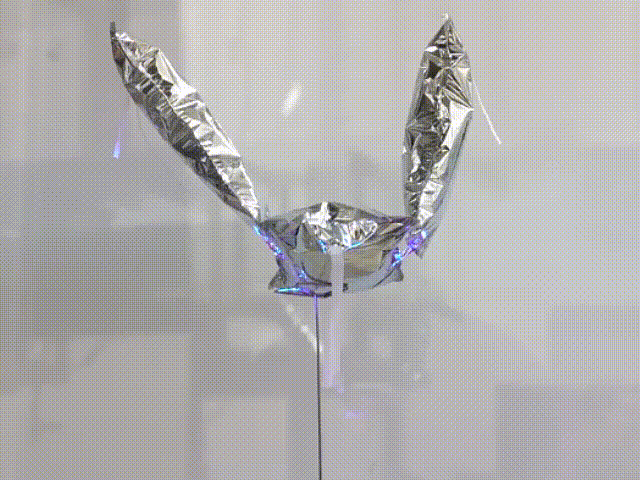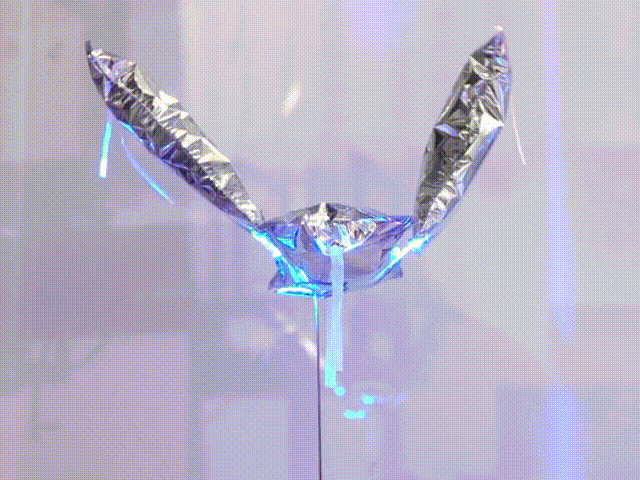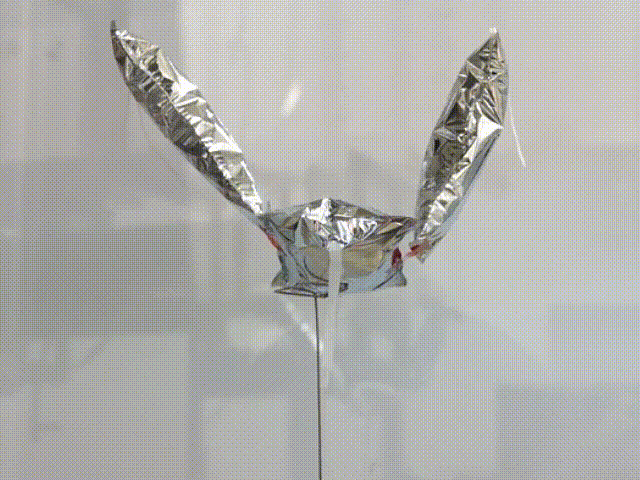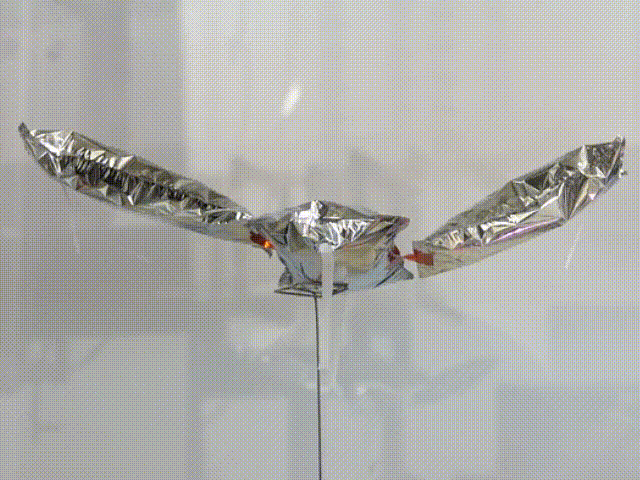
This research explores light-actuated soft flying robots using liquid crystal polymer films driven by projected light. Although the method failed due to material softening under high light intensity, it revealed key insights into light-based actuation.
主要合作者: 马树灯博士, 谢广明教授
该研究探索了基于液晶聚合物薄膜制作光驱动软体飞行机器人的可能性。虽然最终由于液晶材料在高光强度下急剧软化现象而导致项目失败,但我仍认为这是一次有趣的尝试。
Major Collaborator: Qiuyuan Wang, Prof. Jing Yang
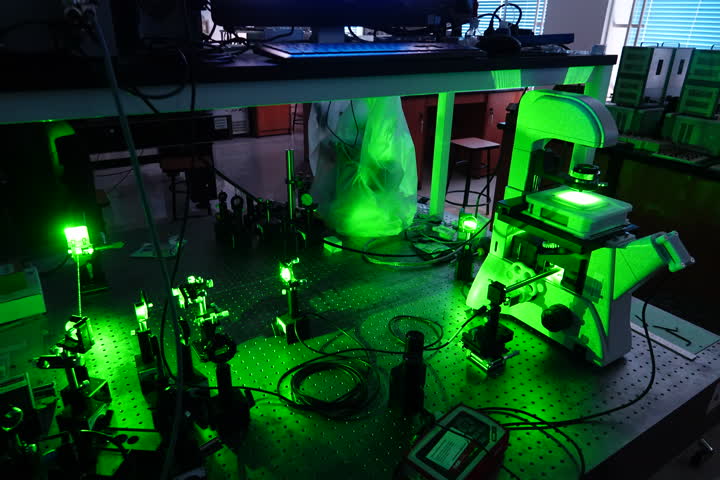
This work focuses on the construction of an optical tweezer with a trapping strength measurement system. We also investigated the possibility for phase-adjustable SPPs optical tweezer array.
Major Collaborator: Tianye Wang
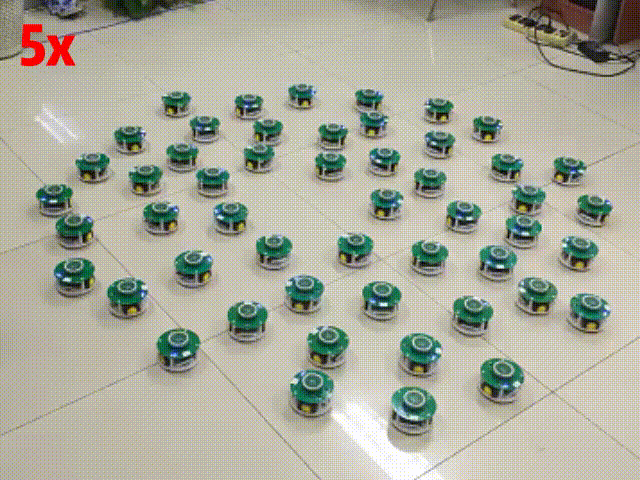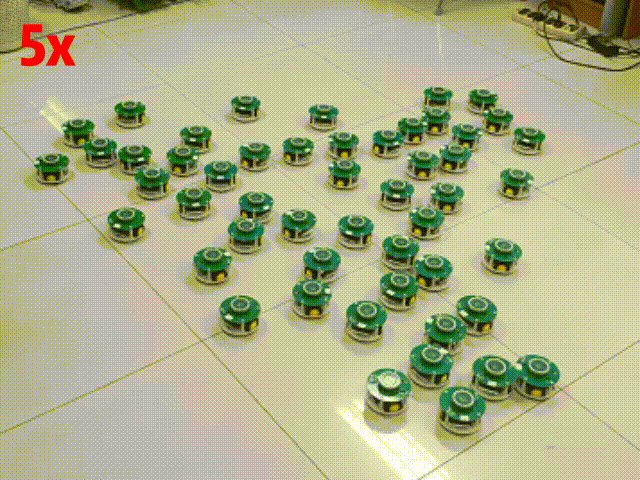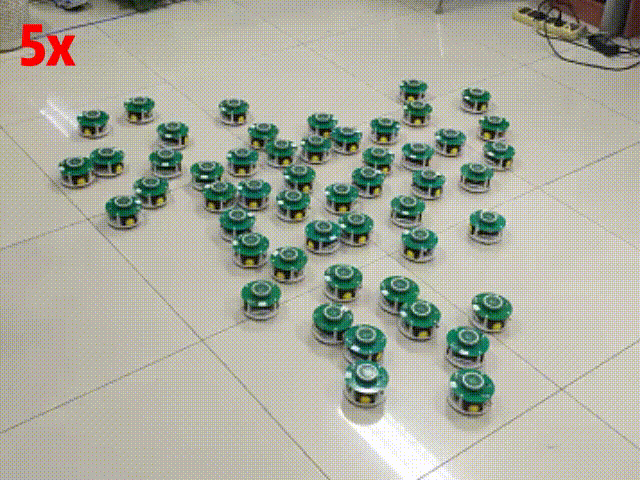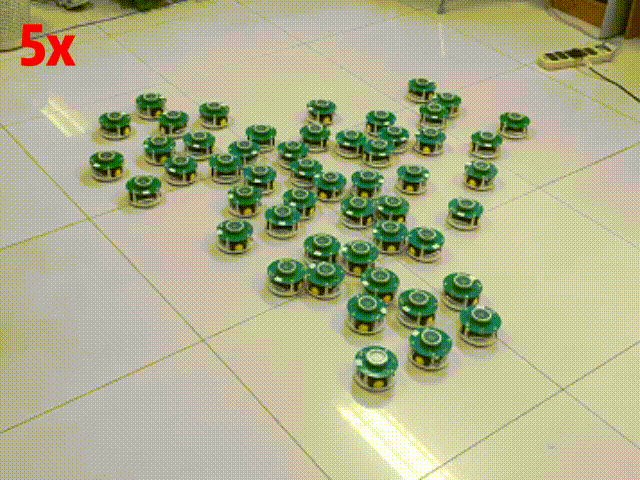
This research proposes a distributed localization algorithm where robots estimate positions by exchanging virtual particles via sensor data only. It enables accurate, anchor-free localization and shape formation, validated in both simulation and real-world swarms.
Jingxian Wang* (co-first author), Chen Yu*, Sam Kriegman, Michael Rubenstein
arXiv preprint, arXiv:2610.24129, 2026.
Jingxian Wang, Chen Yu, David Matthews, Emma Alexander, Sam Kriegman, Michael Rubenstein
Proceedings of Robotics: Science and Systems (RSS), 2026.
Chen Yu*, David Matthews*, Jingxian Wang* (co-first author), Jing Gu, Douglas Blackiston, Michael Rubenstein, Sam Kriegman
Proceedings of the National Academy of Sciences (PNAS), vol. 123, no. 10, article e2519129123, 2026.
Jingxian Wang, Andrew G. Curtis, Mark Yim, Michael Rubenstein
Proceedings of Robotics: Science and Systems (RSS), 2024.
Jingxian Wang, Michael Rubenstein
IEEE International Conference on Robotics and Automation (ICRA), 2026.
Kaixuan Zhang*, Jingxian Wang* (co-first author), Daizong Tian, Thrasyvoulos N. Pappas
ACM Transactions on Graphics (TOG), vol. 42, no. 4, article 63, pp. 1–14, 2023.
Kaixuan Zhang*, Jingxian Wang* (co-first author), Daizong Tian, Thrasyvoulos N. Pappas
U.S. Patent Application Publication, no. US 2024/0312091 A1, 2024.
Best paper finalist, best student paper finalist, best mechanisms and design paper finalist
Jingxian Wang, Michael Rubenstein
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1463–1470, 2022.
Junzheng Zheng, Jingxian Wang, Xin Guo, Chayutpon Huntrakul, Chen Wang, Guangming Xie
IEEE Robotics & Automation Magazine, vol. 29, no. 4, pp. 50–65, 2022.
Jingxian Wang, Tianye Wang, Wei Wang, Xiwang Dong, Yandong Wang
arXiv preprint, arXiv:2006.02658, 2020.
Jingxian Wang, Shuneng Ran, Kun Xun
Physics Experimentation, no. 5, pp. 8–12, 2018.
Advisor: Prof. Michael Rubenstein.
Research focus: full-stack novel robot design, minimalism in robotics, swarm robot, modular robot.
导师:Michael Rubenstein教授
研究方向:全栈新型机器人设计、极简机器人、集群机器人、模块化机器人
Major courses: Theoretical Mechanics, Electrodynamics, Quantum Mechanics, Thermal Physics, Optics, Computational Physics, Modern Physics Lab I and II, Theory of Elasticity, Computational Fluid Mechanics, etc.
主要课程:理论力学、电动力学、量子力学、热学、光学、计算物理、近代物理实验 I & II、 电子线路与实验、弹性力学、计算流体力学等
The 1st cohort of the Early Development Program (EDP).
第一届人大附中超常儿童早期培养实验项目(早培班)
Proposal I wrote "Actively Steerable Femtosat Constellations for In-situ Exploration of Saturn's Rings, Atmosphere, and Magnetosphere" is selected for NASA's NIAC program which has a acceptance rate of ~10%
NASA, 2026
我撰写的提案"主动可控微纳卫星群对土星的环、大气和磁层的原位探测"已入选NASA的NIAC项目,该项目的录取率约为10%
NASA,2026
Undergraduate student Max Hughes advised by me won this award for his research with single rotor drones' sensing.
Northwestern University McCormick School of Engineering, 2026
我指导的本科生Max Hughes因其在单旋翼无人机感知方面的研究获得了这项奖励。
西北大学机械工程学院,2026
For the work "Can Just One Motor Take You to the Sky and Underground?"
Only one Special Prize and two First Prizes were awarded in this competition.
Institute of Physics, Chinese Academy of Sciences, and Bilibili, 2024
Best Paper Finalist
Best Student Paper Finalist
Best Mechanisms and Design Paper Finalist
IROS, 2022
最佳论文奖入围
最佳学生论文奖入围
最佳机构与设计论文奖入围
IROS,2022
Peking University, 2021
北京大学,2021
Awarded for "Light-actuated soft flying robot"
School of Engineering, Peking University, 2021
获奖项目:"光驱动软体飞行机器人"
北京大学工学院,2021
Peking University, 2020
北京大学,2020
Peking University, 2019
北京大学,2019
Peking University, 2018
北京大学,2018
6th place out of 201 students
Peking University, 2018
全年级第6
北京大学,2018
Second Prize
Peking University, 2017
北京大学,2017
18th Asian Physics Olympiad (APhO), 2017
第18届亚洲物理奥林匹克竞赛(APhO),2017
Specialty: Architecting and analyzing novel robot systems, rapid prototyping of hardware and algorithms, multi-paradigm data processing.
Advantages: Extensive experience in novel system design and software-hardware joint development, exposure to latest ideas in robotics, solid background in physics.
Technical Skills:
English Proficiency: TOEFL iBT 114 (out of 120), GRE 327 (out of 340).
专业特长:新型机器人系统的架构与分析、硬件与算法的快速原型设计、多范式数据处理。
优势:在新型系统设计和软硬件联合开发方面有丰富经验,熟知机器人学前沿理念,具有扎实的物理学背景。
技术技能:
英语水平:托福iBT 114分(满分120分),GRE 327分(满分340分)。